Key takeaways
When a manufacturer needs to machine something large and awkward, a wind turbine blade being a very good example, two quite different answers are usually on the table. One is a special purpose machine, built around a single job and very good at it. The other is a robot carrying a cutting tool, flexible enough to do many jobs reasonably well.
Both get pitched as the modern choice, and both have real advantages. The decision is less about which technology is newer and more about one physical property that most comparisons skip over: how stiff the machine is when it is cutting.
This article explains that property, why composite parts change the usual rules, and how the two approaches divide up the work on a wind blade.
What Each One Is
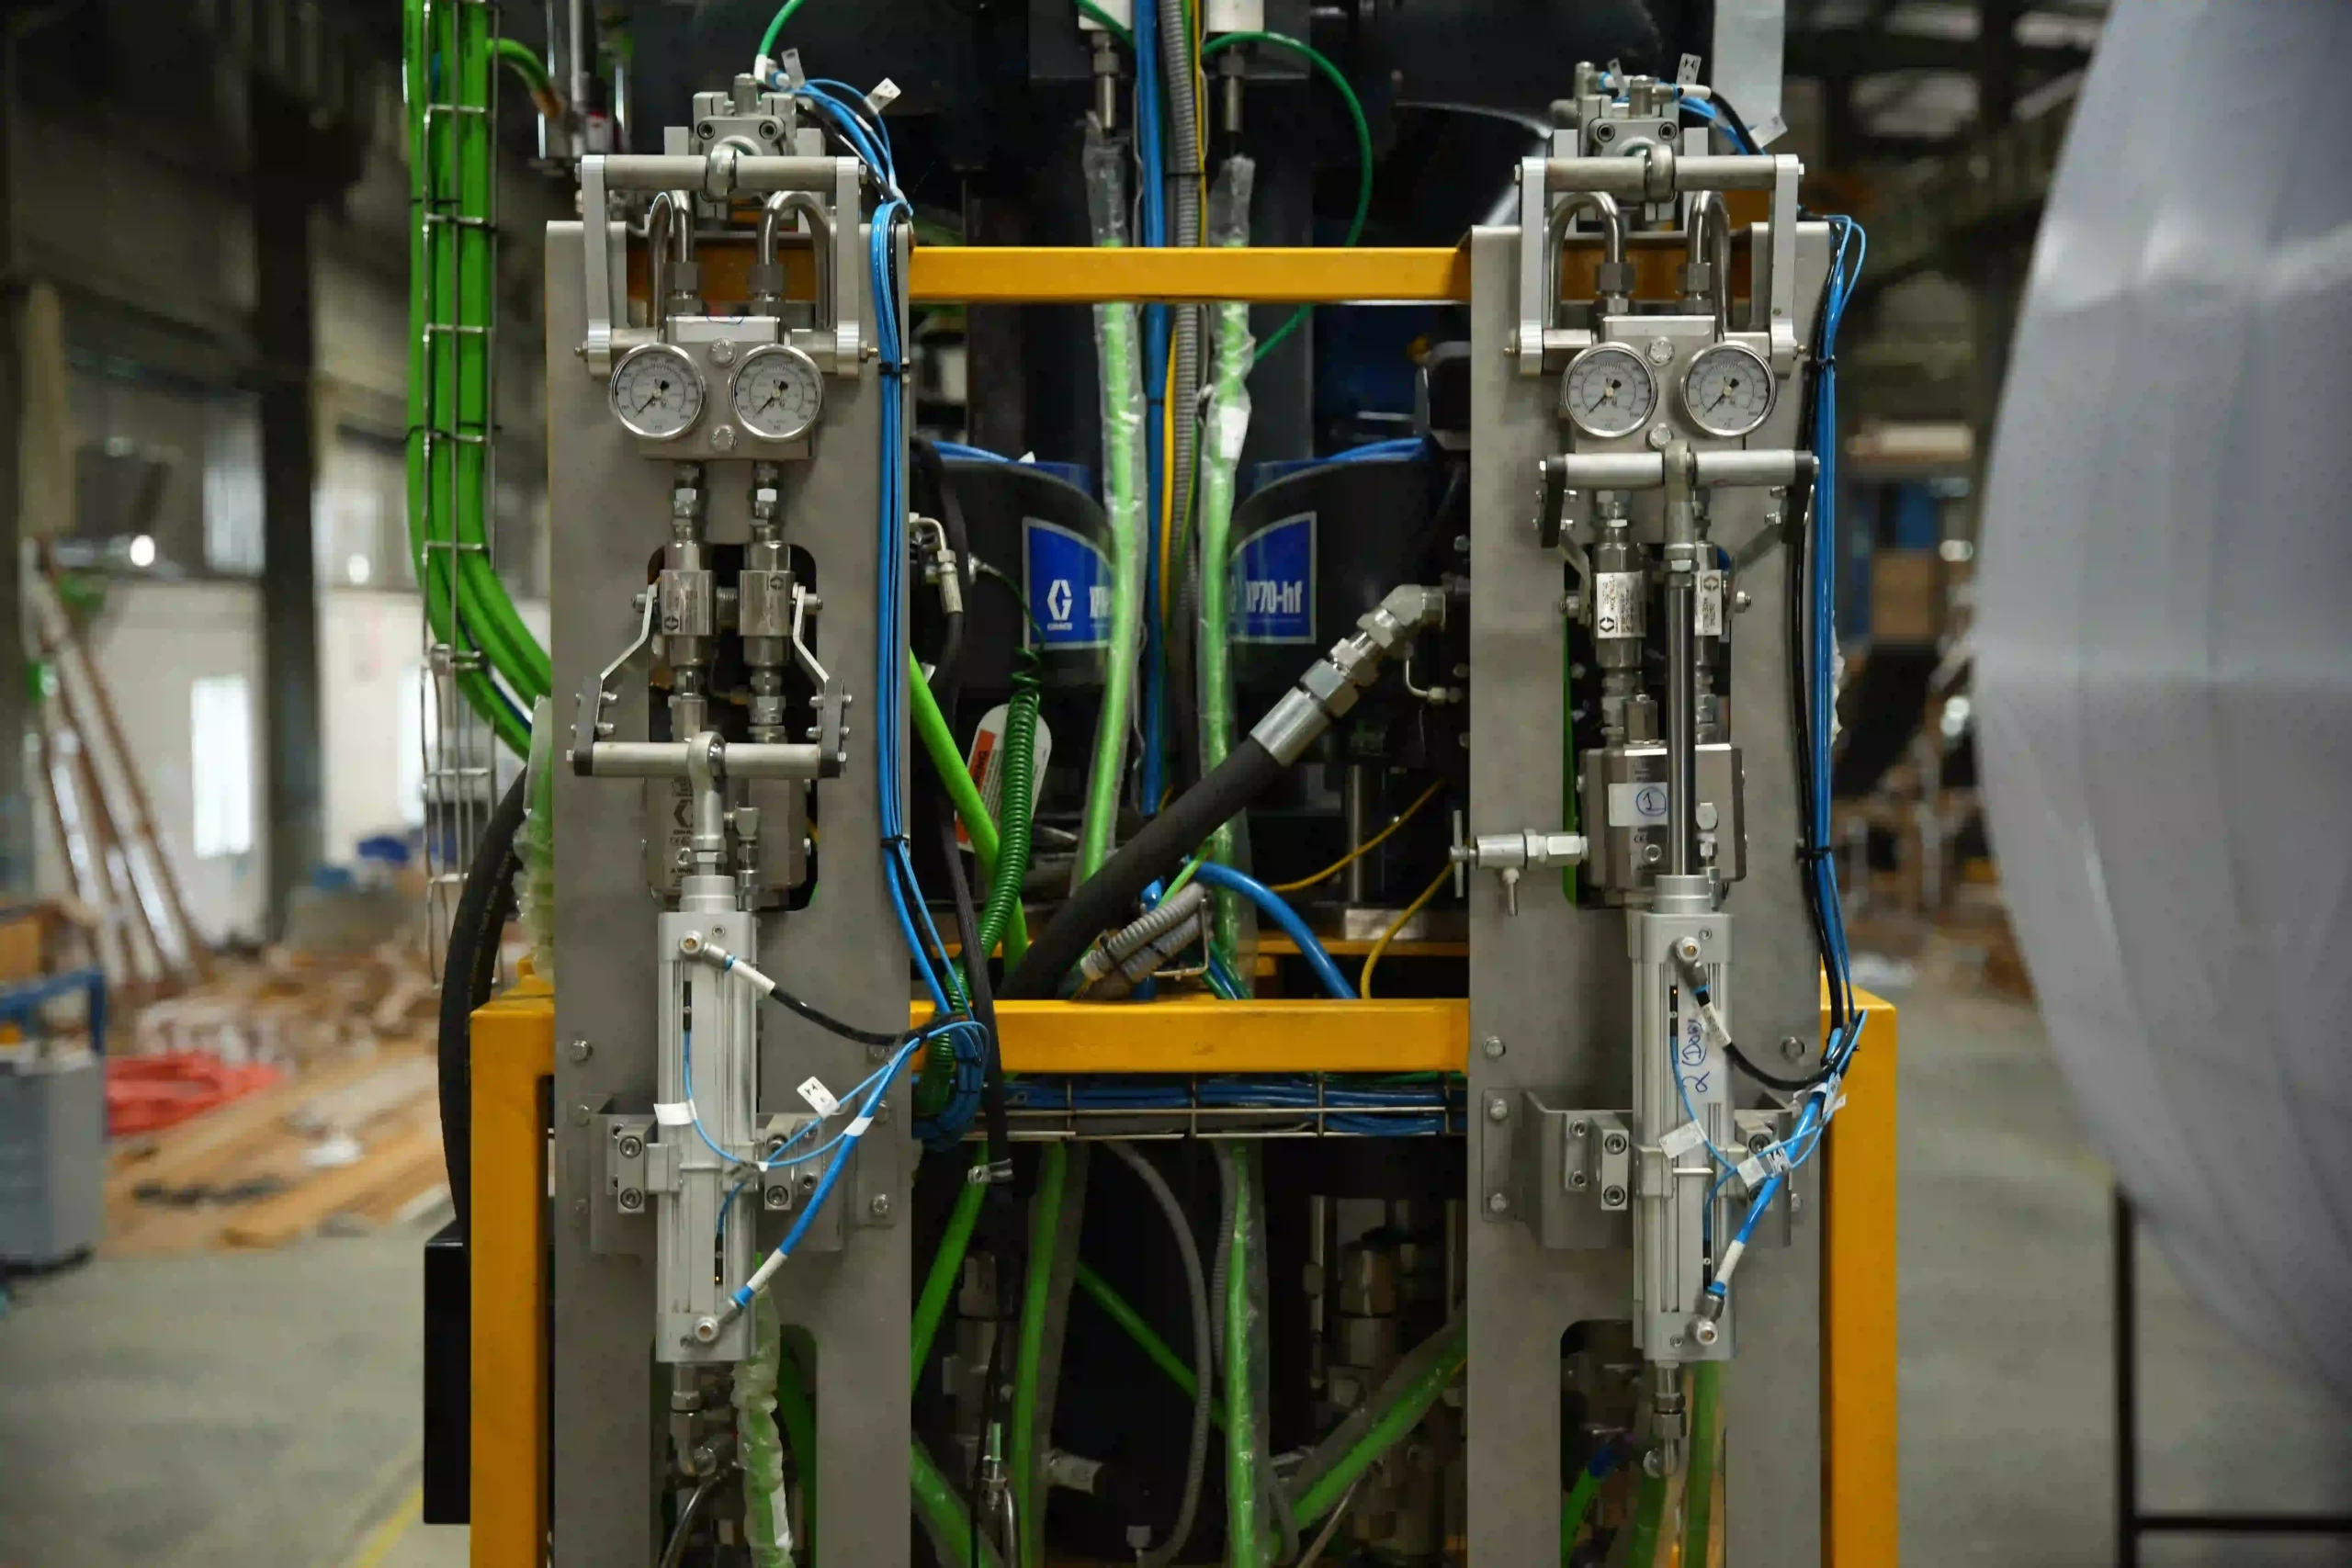
A special purpose machine is designed around a specific operation on a specific family of parts. Its frame, axes and tooling are shaped for that job and nothing else. A machine built to face and drill blade roots, for example, will be sized to a range of root diameters and arranged to work around that circle.
A robotic machining cell starts with a general-purpose industrial robot and fits it with a spindle, drill, saw or grinder. The same arm can be programmed to trim one part, drill another and sand a third. Put it on a linear track or a gantry and its reach extends along parts far longer than the robot itself.
| Special purpose machine | Robotic machining cell | |
|---|---|---|
| Built around | One operation or part family | A general-purpose arm carrying a spindle or tool |
| Stiffness | High, from a rigid structure designed for the cutting load | Much lower, because a jointed arm flexes under force |
| Accuracy | Strong absolute accuracy built into the structure | Good repeatability, weaker absolute accuracy without compensation |
| Flexibility | Limited to what it was designed for | Reprogrammable across parts and operations |
| Reach | Fixed to the part it was built around | Large, and larger still on a track or gantry |
| Programming | Simple and largely fixed | Needs path programming, calibration and often metrology |
| Best suited to | Tight tolerances, heavy cuts, stable part designs | Lighter cuts, varied work, very large parts |
Stiffness Is the Dividing Line
Cutting pushes back. Every time a tool removes material, the material pushes against the tool with a force, and that force tries to move the machine away from the path it was meant to follow.
A special purpose machine resists that push through a rigid structure, often heavy and built specifically for the loads it will see. A robot resists it through a chain of joints and links, each with a little give. Industrial robots are typically far less stiff than dedicated machine tools, often by an order of magnitude or more.
The consequence is direct. Under a heavy cut, a robot deflects, and the tool ends up somewhere slightly different from where it was programmed to be. Deflection also makes vibration more likely, which shows up as chatter on the cut surface and poorer accuracy. The heavier the cut and the tighter the tolerance, the more that matters.
That single property explains most of where each approach fits. Where cutting forces are high and tolerances are tight, stiffness wins and the special purpose machine usually does too. Where forces are modest and flexibility or reach matter more, the robot comes into its own.
Accuracy Is Not the Same as Repeatability
Robot specifications often quote repeatability, and the figures look impressive. Repeatability describes how closely a robot returns to the same point it has visited before. It says much less about absolute accuracy, meaning how closely it reaches a point defined in space for the first time.
Machining needs absolute accuracy. A bolt hole has to be in the right place on the part, not just in the same place as the last hole. Robots can be made considerably more accurate through calibration, compensation for deflection and external measurement, often using laser trackers or vision to correct the path. That works, and it adds cost, programming effort and another system that has to be maintained.
A special purpose machine gets its accuracy mostly from its structure. That is less flexible but also less dependent on correction systems staying calibrated.
Why Composites Change the Calculation
Here is the nuance that makes this comparison different for wind blades than for, say, steel parts.
Machining fiber composites generally involves much lower cutting forces than machining steel. Lower forces mean less deflection, which moves many composite operations into territory where a robot performs well. Trimming a composite edge or drilling through a laminate can be entirely practical for a robot, where the same operation in hardened steel would not be.
Composites bring their own difficulties, though. Fibers can break out or the laminate can delaminate where a drill exits or a cutter leaves the edge, and composite dust is abrasive and needs extraction. Robots handling drilling often use a pressure foot, a device that clamps against the surface around the hole, to stabilize the tool and reduce exit damage. The point is that lower forces widen the range where robots work, without making composite machining easy.
How the Work Divides on a Wind Blade
A blade is one of the few parts where both approaches clearly have a place, often in the same factory.
| Blade operation | Usual fit | Why |
|---|---|---|
| Root face milling | Special purpose machine | A flat, square face across a large diameter needs stiffness and absolute accuracy |
| Root bolt hole drilling | Special purpose machine | Hole position and perpendicularity over a long hole depend on a rigid setup |
| Root end cutting | Either, depending on setup | A cut across the root can be done with a dedicated saw or a well-supported robot |
| Edge trimming along the blade | Robot on a track or gantry | The part is tens of meters long, and trimming forces in composite are modest |
| Grinding and sanding | Robot | Varied surfaces, dusty and physically demanding work suited to automation |
| Inspection and measurement | Robot | Scanners and sensors can be carried along the blade without heavy loads |
The root favors dedicated machines
The blade root is where tolerances are tightest and consequences most serious. The face has to be flat and square across a diameter of several meters, and every bolt hole has to sit accurately on its pitch circle and run square to the face over a considerable depth. Errors load the bolts unevenly, which becomes a fatigue problem over the blade’s life. The reasons are covered in the article on wind turbine blade root manufacturing.
Perpendicularity over a long hole is especially demanding, because any flex in the machine during drilling shows up as a hole that wanders off axis. That is exactly where structural stiffness pays for itself.
The type of root joint changes the detail. T-bolt roots rely heavily on precise axial and radial drilling, while insert roots shift more of the effort into molding and bonding, a comparison set out in the piece on T-bolt versus embedded insert root joints.
The rest of the blade favors robots
Along the blade the picture reverses. Blades run to tens of meters, so a dedicated machine enclosing the whole part would be enormous and inflexible. A robot on a track or gantry can travel along the blade trimming edges, and because trimming forces in composite are modest, its lower stiffness is rarely the limiting factor.
Grinding and sanding are even clearer. The surfaces vary, the work is dusty and physically hard on people, and the forces involved are light. It is one of the strongest cases for robotic automation anywhere in blade production.
Hybrid Setups
Many plants end up with both, and the combination is often the right answer rather than a compromise.
A dedicated machine handles the operations where accuracy and stiffness decide the outcome, most obviously the root. Robots handle the operations where reach, variety and flexibility matter more, such as trimming, finishing and inspection. Each does the work it is suited to, and neither is forced into a job it handles poorly.
The alternative, pushing one technology to cover everything, usually shows. A robot asked to hold root tolerances needs extensive compensation and may still struggle. A dedicated machine asked to trim a hundred meters of blade edge becomes impractically large.
Flexibility and Blade Design Changes
One argument for robots deserves a fair hearing: blade designs change, and they have been getting longer for years.
A special purpose machine covers a defined range. Root machining systems are typically sized to a span of pitch circle diameters, and a blade outside that span needs a different machine. A robot can be reprogrammed for a new part, which makes it more resilient to design change.
That flexibility is worth weighing against what the operation demands. For trimming and finishing, where designs vary and tolerances are looser, flexibility is valuable. For the root, where the tolerance requirement is what matters most, buying a machine sized for the range of roots a plant expects to build is usually a sounder decision than accepting a flexible machine that struggles to hold the tolerance.
 “The strongest automation strategy combines dedicated machines for precision-critical operations with robots for tasks where reach, flexibility, and adaptability matter most.”
See it in action
Cost Over the Life of the Equipment
Comparing purchase prices alone gives a misleading answer.
Robots can look cheaper at the outset, but machining-grade robotic cells often need calibration systems, external metrology, specialist programming and periodic re-verification to stay accurate. Those costs recur. Special purpose machines usually cost more to buy and less to keep accurate, but they carry the risk of becoming stranded if the part they were built for changes beyond their range.
The fair comparison looks at cost per good part over the expected life of the operation, including scrap from missed tolerances, programming and calibration effort, and the likelihood that the part design will change.
A Short Decision Guide
- Tight tolerance with meaningful cutting force: lean toward a special purpose machine.
- Very large part with modest cutting force: lean toward a robot on a track or gantry.
- Many different parts or frequent design changes: robots gain ground.
- Stable, high-volume, single operation: a dedicated machine usually gives the lowest cost per part.
- Dusty, repetitive, physically demanding finishing: a strong case for robots.
- A mix of all the above: expect a hybrid, and plan it that way from the start.
Both Approaches at Cybernetik
Cybernetik works on both sides of this comparison. Its wind energy automation range includes the TurboMac systems dedicated to blade root machining, and the company has delivered more than 400 custom robotic automation solutions across industries.
| Cybernetik wind machining capability | Specification |
|---|---|
| TurboMac 3000 | Root machining for pitch circle diameters of 2,800 to 3,000 mm, blades around 65 to 70 m |
| TurboMac 4800 | Root machining for pitch circle diameters of 3,000 to 4,800 mm, blades up to around 100 m |
| Pitch circle accuracy | PCD within plus or minus 1 mm |
| Face milling | Milling flatness within 0.500 mm |
| Hole accuracy | Hole perpendicularity within plus or minus 0.250 mm |
| Robotics experience | More than 400 custom robotic automation solutions delivered |
| Wind customers | Work delivered for blade makers including Siemens Gamesa and Suzlon |
That combination matters because it removes the usual bias in this decision. A supplier that only builds robots will recommend robots, and one that only builds dedicated machines will recommend those. Having both lets the recommendation follow the operation: dedicated root machining where accuracy and stiffness decide the result, robotic cells where reach and flexibility count for more.
How root machining and finishing fit into the full production flow is covered in the guide to wind turbine blade manufacturing.
Cybernetik has been building automation for more than three decades. It is headquartered in Pune with facilities in Gujarat and Raigad and offices in the United States and UAE, and has installed over 6,000 systems in more than 30 countries. More background is on the Cybernetik about page.